Zirui Zou outdoors beside a lake

Zirui Zou 邹子瑞

Undergraduate Student

Robotics Engineering
Zhejiang University

About Me

I am an undergraduate student in Robotics Engineering at Zhejiang University, advised by Prof. Qiuguo Zhu. I was fortunate to undertake a research internship at the Tsinghua Embodied AI Lab (TEA Lab), Institute for Interdisciplinary Information Sciences (IIIS), Tsinghua University, under the supervision of Prof. Huazhe Xu. I will join the Autonomous Robots Lab (ARL) at Peking University in the fall to pursue a master’s degree under the supervision of Prof. Chang Liu.

I am drawn to embodied intelligence and the possibility of bringing greater intelligence to robots—helping them understand their surroundings, learn from experience, and act effectively in the physical world.

Research Interests

  • Dexterous Manipulation. Integrating multimodal data, including vision, touch, and proprioception, to improve task success and robustness in dexterous manipulation.
  • Whole-Body Motion Control. Exploring foundation models for humanoid motion that generalize across tasks and environments while coordinating the entire body.
  • Cooperative Multi-Agent Reinforcement Learning. Studying temporal credit assignment and predictive representation learning to improve coordination under sparse and delayed rewards.

Publications

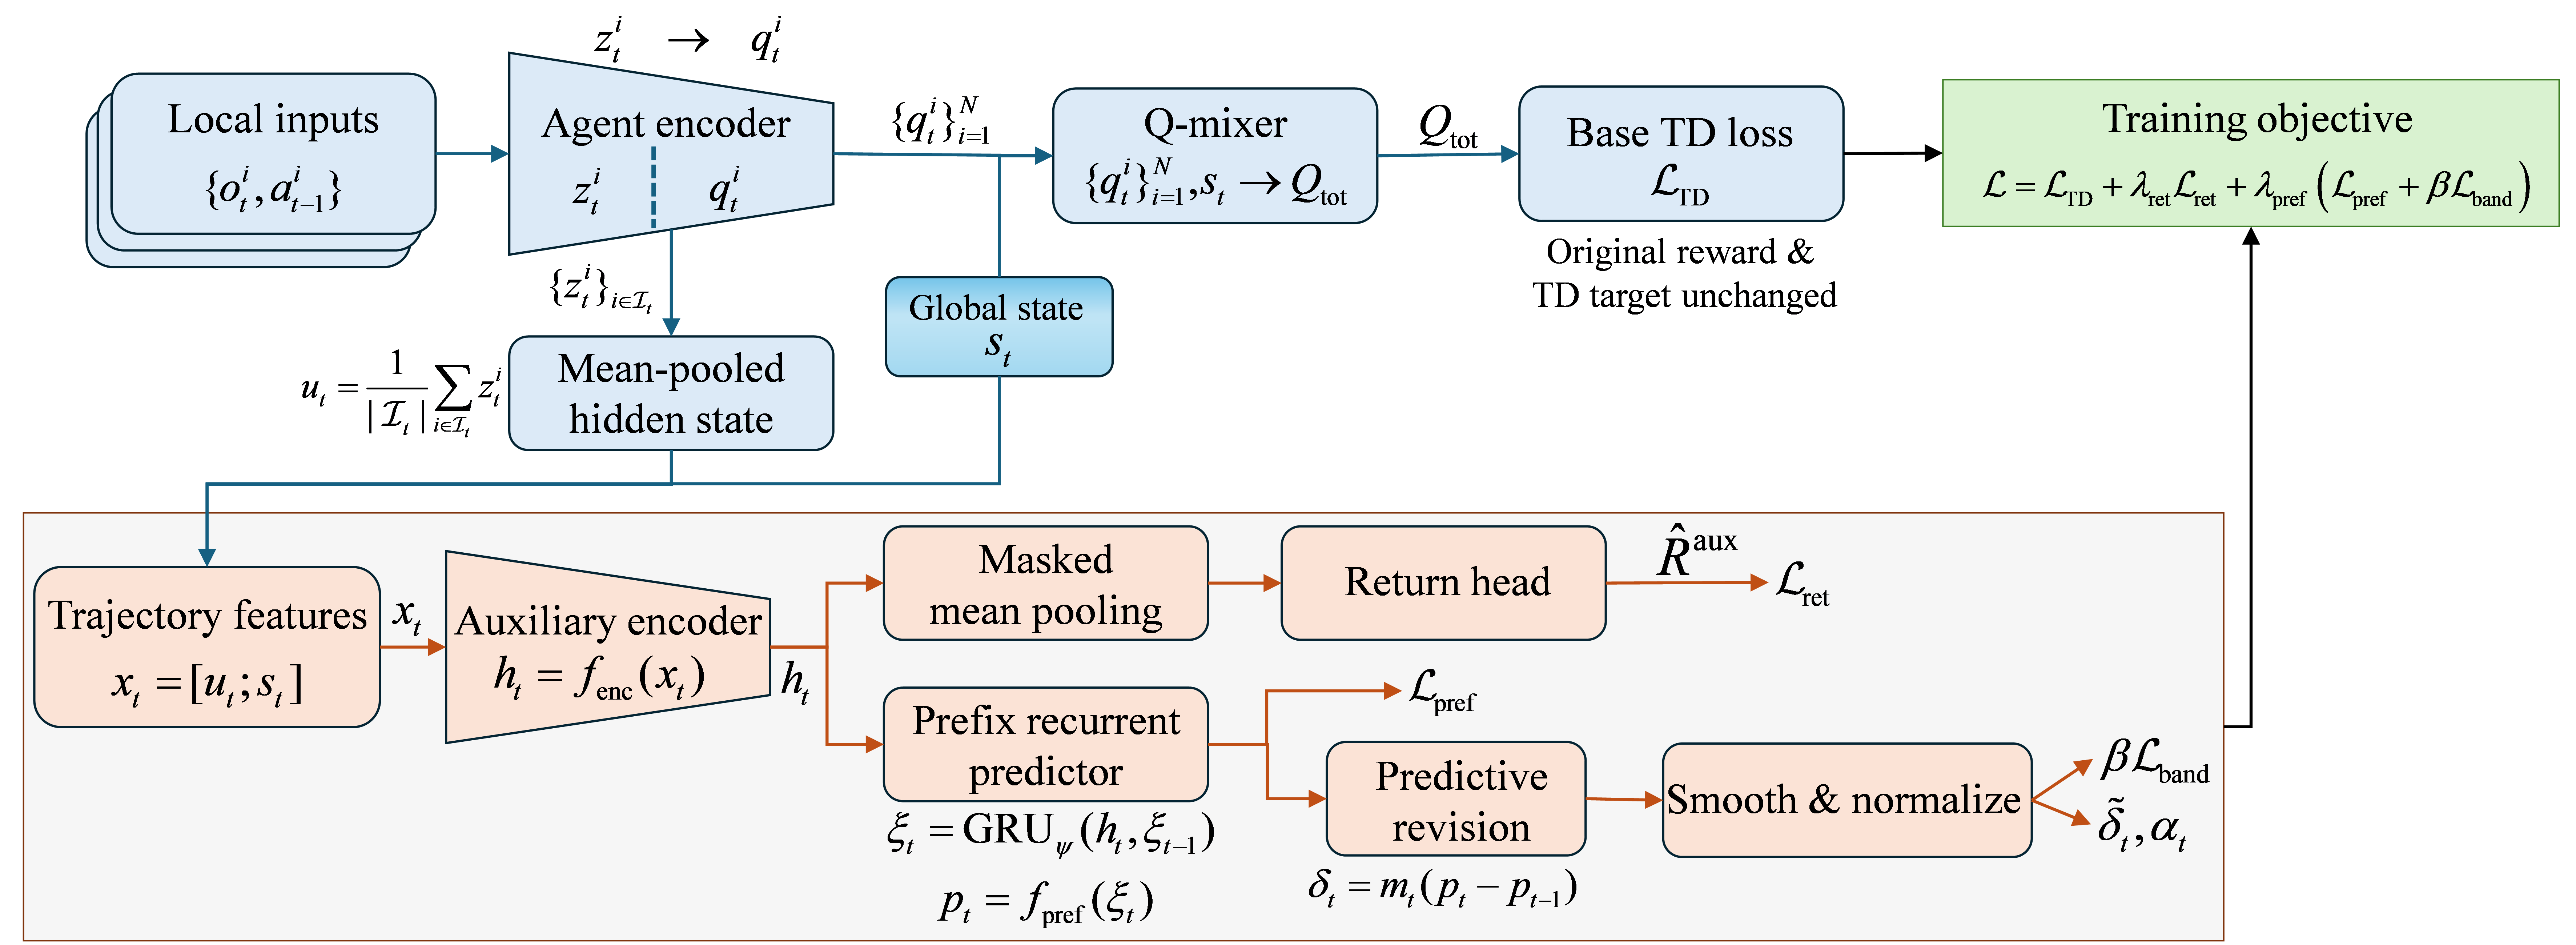
PPTA architecture combining episode-level return prediction and prefix-based predictive temporal attribution
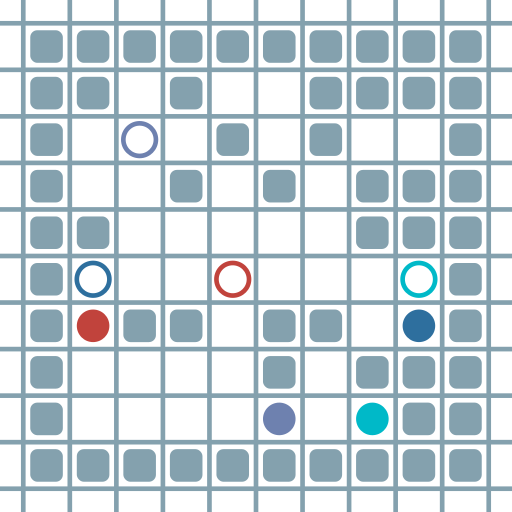
Official POGEMA A-star demonstration: agents navigate a grid around obstacles to reach their goals
POGEMA ↗Official environment demo
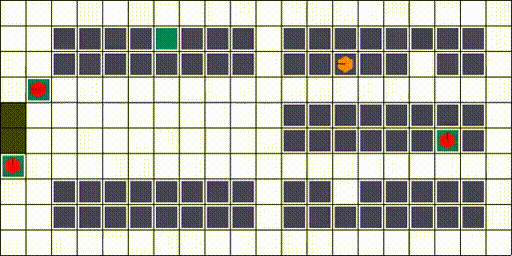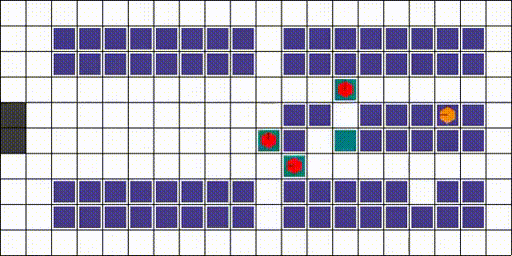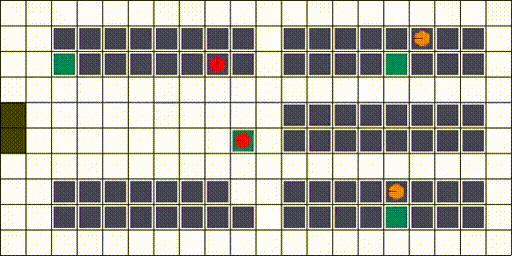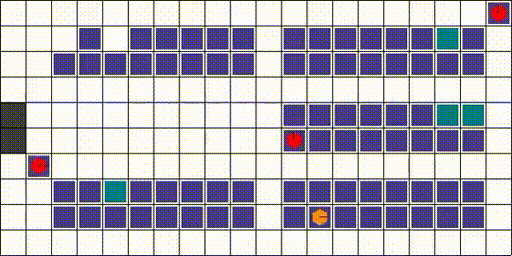
Official RWARE animation showing multiple warehouse robots collecting and delivering shelves
RWARE ↗Official environment demo

Prefix-Based Predictive Temporal Attribution for Cooperative Multi-Agent Reinforcement Learning

Zirui Zou, Qiuguo Zhu

Frontiers of Information Technology & Electronic Engineering (FITEE) Accepted

PPTA uses prefix-conditioned return prediction as an auxiliary learning signal to improve cooperative decision-making under sparse, delayed rewards, while retaining the environment reward and host learning targets.

Education

Peking University

Incoming · Fall

Incoming Master’s Student

Autonomous Robots Lab (ARL)
Advisor: Prof. Chang Liu
Zhejiang University

Undergraduate

Robotics Engineering

Advisor: Prof. Qiuguo Zhu

Research Experience

Latent Verse Beijing, China

Jul. 2026 – Present

Research Intern

TEA Lab, IIIS, Tsinghua University

Feb. 2026 – Jul. 2026

Research Intern

Advisor: Prof. Huazhe Xu

Zhejiang University RoboCup Team

Oct. 2024 – May 2026

Team Leader, 3D Simulation

Honors & Awards

  • Runner-up, RoboCup China Open, Humanoid Small Size League, Beijing.
  • National First Prize, RoboCup China Open, Simulation League.
  • Second Prize, RoboCup World Championship, Humanoid League, Incheon, South Korea.

Based on the Minimal Light academic homepage template.